A virtual implementation of a model base library. More...
#include <GenericModel.hpp>
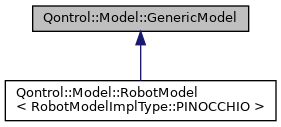
Public Member Functions | |
| void | setRobotState (const RobotState &robot_state) |
| Load the robot model given a urdf path. More... | |
| auto | getRobotState () -> RobotState |
| Get the robot state (position, velocity, acceleration, and external torque) More... | |
| virtual auto | getTipFrameName () -> std::string=0 |
| Get the name of the tip frame in the model. More... | |
| virtual auto | getRootFrameName () -> std::string=0 |
| Get the name of the root frame in the model. More... | |
| virtual auto | getNrOfDegreesOfFreedom () -> int=0 |
| Get the robot number of degrees of freedom. More... | |
| virtual void | setJointPosition (Eigen::VectorXd joint_position) |
| Set the robot current joint position. More... | |
| virtual auto | getJointPosition () -> Eigen::VectorXd |
| get the robot current joint position More... | |
| void | setLowerJointPositionLimits (Eigen::VectorXd lim) |
| Set the robot lower joint position limits. More... | |
| void | setUpperJointPositionLimits (Eigen::VectorXd lim) |
| Set the robot upper joint position limits. More... | |
| virtual auto | getLowerJointPositionLimits () -> Eigen::VectorXd |
| Get the robot lower joint position limits. More... | |
| virtual auto | getUpperJointPositionLimits () -> Eigen::VectorXd |
| Get the robot upper joint position limits. More... | |
| virtual void | setJointVelocity (Eigen::VectorXd joint_velocity) |
| Set the robot current joint velocity. More... | |
| virtual auto | getJointVelocity () -> Eigen::VectorXd |
| Get the robot current joint velocity. More... | |
| void | setJointVelocityLimits (Eigen::VectorXd lim) |
| Set the robot joint velocity limts. More... | |
| auto | getJointVelocityLimits () -> Eigen::VectorXd |
| Get the robot joint velocity limts. More... | |
| virtual void | setJointAcceleration (Eigen::VectorXd joint_acceleration) |
| Set the robot current joint acceleration. More... | |
| virtual auto | getJointAcceleration () -> Eigen::VectorXd |
| Get the robot current joint acceleration. More... | |
| virtual void | setJointTorque (Eigen::VectorXd joint_torque) |
| Set the robot current joint torque. More... | |
| virtual auto | getJointTorque () -> Eigen::VectorXd |
| Get the robot current joint torque. More... | |
| void | setJointTorqueLimits (Eigen::VectorXd lim) |
| Set the robot joint torque limits. More... | |
| auto | getJointTorqueLimits () -> Eigen::VectorXd |
| Get the robot joint torque limits. More... | |
| virtual void | setExternalJointTorque (Eigen::VectorXd external_joint_torque) |
| Set the robot current external joint torque. More... | |
| virtual auto | getExternalJointTorque () -> Eigen::VectorXd |
| Get the robot current external joint torque. More... | |
| virtual auto | getJointCoriolisTorques () -> Eigen::VectorXd=0 |
| Get the vector representing the gravity effect associated to the \(g\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state. More... | |
| virtual auto | getJointInertiaMatrix () -> Eigen::MatrixXd=0 |
| Get the matrix representing the joint space inertia matrix associated to the \(M(q)\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state. More... | |
| virtual auto | getInverseJointInertiaMatrix () -> Eigen::MatrixXd=0 |
| Get the matrix representing the inverse of the joint space inertia matrix associated to the \(M(q)\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state. More... | |
| virtual auto | getFramePose (const std::string &body_name) -> Eigen::Isometry3d=0 |
| Get the pose of the frame called \(\text_it{body_name}\) in the URDF wrt. the root frame. More... | |
| virtual auto | getTipFramePose () -> Eigen::Isometry3d=0 |
| Get the pose of the tip frame wrt. the root frame. More... | |
| virtual auto | getJacobian (const std::string &body_name) -> Eigen::MatrixXd=0 |
| Get the Jacobian matrix expressed at the frame name \(\textit{body_name}\) in the URDF wrt. the root frame. More... | |
| virtual auto | getJacobian (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::MatrixXd=0 |
| virtual auto | getJacobian (const std::string &body_name, ReferenceFrame ref_frame) -> Eigen::MatrixXd=0 |
| virtual auto | getJacobianTimeDerivativeQdot (const std::string &body_name) -> Eigen::VectorXd=0 |
| Get the vector representing the \(\dot{J}\dot{q}\) terme in the equation \(\dot{twist} = \dot{J}\dot{q} + J\ddot{q}\). More... | |
| virtual auto | getJacobianTimeDerivativeQdot (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::VectorXd=0 |
| Get the vector representing the \(\dot{J}\dot{q}\) terme in the equation \(\dot{twist} = \dot{J}\dot{q} + J\ddot{q}\). More... | |
| virtual auto | getJacobianTimeDerivativeQdot (const std::string &body_name, ReferenceFrame ref_frame) -> Eigen::VectorXd=0 |
| virtual auto | getFrameVelocity (const std::string &body_name) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the twist representing the velocity of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame. More... | |
| virtual auto | getFrameVelocity (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the twist representing the \(\textit{frame}\) velocity wrt. the root frame. More... | |
| virtual auto | getTipFrameVelocity () -> Eigen::Matrix< double, 6, 1 >=0 |
| The twist representing the velocity of the tip frame wrt. the root frame. More... | |
| virtual auto | getJointAccelerationFromTorques (Eigen::VectorXd torque) -> Eigen::VectorXd=0 |
| virtual auto | getFrameAccelerationFromJointAcceleration (const std::string &body_name) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/acceleration. More... | |
| virtual auto | getFrameAccelerationFromJointAcceleration (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/acceleration. More... | |
| virtual auto | getFrameAccelerationFromTorques (const std::string &body_name) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/torque/external torque. More... | |
| virtual auto | getFrameAccelerationFromTorques (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/torque/external torque. More... | |
| virtual auto | getExternalWrench (const std::string &body_name) -> Eigen::Matrix< double, 6, 1 >=0 |
| Get the external wrench applied on the named \(\textit{body_name}\) in the URDF wrt. the root frame given the external joint torques applied on the robot. More... | |
| virtual auto | getExternalWrench (const std::string &body_name, const Eigen::Isometry3d &frame) -> Eigen::Matrix< double, 6, 1 >=0 |
| auto | integrate (Eigen::VectorXd q, Eigen::VectorXd v, double dt) -> Eigen::VectorXd |
Static Public Member Functions | |
| static auto | skew (Eigen::Vector3d vector) -> Eigen::Matrix3d |
| compute the skew symetry matrix of a vector. Usefull to perform cross products More... | |
Detailed Description
A virtual implementation of a model base library.
Enum listing the model library that are implemented
<
Member Function Documentation
◆ getExternalJointTorque()
|
virtual |
Get the robot current external joint torque.
- Returns
- A \(ndof\) vector representing the external torque measured on each joint (in Nm for a revolute joint and N for a prismatic joint )
◆ getExternalWrench()
|
pure virtual |
Get the external wrench applied on the named \(\textit{body_name}\) in the URDF wrt. the root frame given the external joint torques applied on the robot.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- Eigen::Vector6d
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameAccelerationFromJointAcceleration() [1/2]
|
pure virtual |
Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/acceleration.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- Eigen::Vector6d
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameAccelerationFromJointAcceleration() [2/2]
|
pure virtual |
Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/acceleration.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- Eigen::Vector6d
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameAccelerationFromTorques() [1/2]
|
pure virtual |
Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/torque/external torque.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- Eigen::Vector6d
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameAccelerationFromTorques() [2/2]
|
pure virtual |
Get the acceleration of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame given the robot current joint position/velocity/torque/external torque.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- Eigen::Vector6d
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFramePose()
|
pure virtual |
Get the pose of the frame called \(\text_it{body_name}\) in the URDF wrt. the root frame.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- an Isometry.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameVelocity() [1/2]
|
pure virtual |
Get the twist representing the velocity of the frame named \(\textit{body_name}\) in the URDF wrt. the root frame.
- Parameters
-
body_name The name of the frame in the urdf.
- Returns
- a twist.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getFrameVelocity() [2/2]
|
pure virtual |
Get the twist representing the \(\textit{frame}\) velocity wrt. the root frame.
- Parameters
-
frame A frame expressed wrt. the root frame.
- Returns
- A twist
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getInverseJointInertiaMatrix()
|
pure virtual |
Get the matrix representing the inverse of the joint space inertia matrix associated to the \(M(q)\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state.
- Returns
- A \(ndof \times ndof\) matrix
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJacobian() [1/2]
|
pure virtual |
Get the Jacobian matrix expressed at the frame name \(\textit{body_name}\) in the URDF wrt. the root frame.
- Parameters
-
body_name The name of the frame in the urdf
- Returns
- A \(6 \times ndof\) Jacobian matrix.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJacobian() [2/2]
|
pure virtual |
- Parameters
-
frame A frame expressed wrt. the root frame.
- Returns
- A \(6 \times ndof\) Jacobian matrix expressed at the \(\textit{frame}\) pose wrt. the root frame.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJacobianTimeDerivativeQdot() [1/2]
|
pure virtual |
Get the vector representing the \(\dot{J}\dot{q}\) terme in the equation \(\dot{twist} = \dot{J}\dot{q} + J\ddot{q}\).
- Parameters
-
body_name The name of the frame in the urdf
- Returns
- A \(6\) vector
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJacobianTimeDerivativeQdot() [2/2]
|
pure virtual |
Get the vector representing the \(\dot{J}\dot{q}\) terme in the equation \(\dot{twist} = \dot{J}\dot{q} + J\ddot{q}\).
- Parameters
-
body_name The name of the frame in the urdf
- Returns
- A \(6\) vector
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJointAcceleration()
|
virtual |
Get the robot current joint acceleration.
- Returns
- A \(ndof\) vector representing the current robot joint acceleration
◆ getJointCoriolisTorques()
|
pure virtual |
Get the vector representing the gravity effect associated to the \(g\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state.
- Returns
- A f$ndof \( vector . */ virtual auto getJointGravityTorques() -> Eigen::VectorXd = 0; /** @brief Compute joint friction and damping according to "Dynamic Identification of the KUKA LBR iiwa Robot With Retrieval of Physical Parameters Using Global Optimization", 2020 : \) F_{v}{q} + F_{c} sign(\dot{q}) \f$.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJointInertiaMatrix()
|
pure virtual |
Get the matrix representing the joint space inertia matrix associated to the \(M(q)\) term in the equation of motion: \( M(q)\ddot{q} + c(q, \dot{q}) + g(q) = \tau \). Taken at the current robot state.
- Returns
- A \(ndof \times ndof\) matrix
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getJointPosition()
|
virtual |
get the robot current joint position
- Returns
- A \(ndof\) vector representing the current robot joint position
◆ getJointTorque()
|
virtual |
Get the robot current joint torque.
- Returns
- A \(ndof\) vector representing the current robot joint torque
◆ getJointTorqueLimits()
| auto Qontrol::Model::GenericModel::getJointTorqueLimits | ( | ) | -> Eigen::VectorXd |
Get the robot joint torque limits.
- Returns
- The robot torque limits
◆ getJointVelocity()
|
virtual |
Get the robot current joint velocity.
- Returns
- A \(ndof\) vector representing the current robot joint velocity
◆ getJointVelocityLimits()
| auto Qontrol::Model::GenericModel::getJointVelocityLimits | ( | ) | -> Eigen::VectorXd |
Get the robot joint velocity limts.
- Returns
- The robot velocity limits
◆ getLowerJointPositionLimits()
|
virtual |
Get the robot lower joint position limits.
- Returns
- The robot lower position limits
◆ getNrOfDegreesOfFreedom()
|
pure virtual |
Get the robot number of degrees of freedom.
- Returns
- The robot number of degrees of freedom
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getRobotState()
| auto Qontrol::Model::GenericModel::getRobotState | ( | ) | -> RobotState |
Get the robot state (position, velocity, acceleration, and external torque)
- Returns
- The robot state
◆ getRootFrameName()
|
pure virtual |
Get the name of the root frame in the model.
- Returns
- The name of the root frame
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getTipFrameName()
|
pure virtual |
Get the name of the tip frame in the model.
- Returns
- The name of the tip frame
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getTipFramePose()
|
pure virtual |
Get the pose of the tip frame wrt. the root frame.
- Returns
- an Isometry.
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getTipFrameVelocity()
|
pure virtual |
The twist representing the velocity of the tip frame wrt. the root frame.
- Returns
- A twist
Implemented in Qontrol::Model::RobotModel< ModelImpl::PINOCCHIO >.
◆ getUpperJointPositionLimits()
|
virtual |
Get the robot upper joint position limits.
- Returns
- The robot upper position limits
◆ setExternalJointTorque()
|
virtual |
Set the robot current external joint torque.
- Parameters
-
external_joint_torque the robot external joint torque
◆ setJointAcceleration()
|
virtual |
Set the robot current joint acceleration.
- Parameters
-
joint_acceleration the robot current joint acceleration
◆ setJointPosition()
|
virtual |
Set the robot current joint position.
- Parameters
-
joint_position the robot current joint position
◆ setJointTorque()
|
virtual |
Set the robot current joint torque.
- Parameters
-
joint_torque the robot current joint torque
◆ setJointTorqueLimits()
| void Qontrol::Model::GenericModel::setJointTorqueLimits | ( | Eigen::VectorXd | lim | ) |
Set the robot joint torque limits.
- Parameters
-
lim The robot upper velocity limits
- Remarks
- This functions is automatically called by loadModelFromString to set the joint torque limits according to the urdf model
◆ setJointVelocity()
|
virtual |
Set the robot current joint velocity.
- Parameters
-
joint_velocity the robot current joint velocity
◆ setJointVelocityLimits()
| void Qontrol::Model::GenericModel::setJointVelocityLimits | ( | Eigen::VectorXd | lim | ) |
Set the robot joint velocity limts.
- Parameters
-
lim The robot velocity limits
- Remarks
- This functions is automatically called by loadModelFromString to set the joint velocity limits according to the urdf model
◆ setLowerJointPositionLimits()
| void Qontrol::Model::GenericModel::setLowerJointPositionLimits | ( | Eigen::VectorXd | lim | ) |
Set the robot lower joint position limits.
- Parameters
-
lim The robot lower position limits
- Remarks
- This functions is automatically called by loadModelFromString to set the lower joint position limits according to the urdf model
◆ setRobotState()
| void Qontrol::Model::GenericModel::setRobotState | ( | const RobotState & | robot_state | ) |
Load the robot model given a urdf path.
- Parameters
-
urdf_path a urdf string representing the robot description root_link The name of the root link in the urdf file. By default the first link in the urdf is taken. tip_link The name of the tip link in the urdf file. By default the last link in the urdf is taken.
Sets the robot state (position, velocity, acceleration, and external torque)
- Parameters
-
robot_state the robot state
◆ setUpperJointPositionLimits()
| void Qontrol::Model::GenericModel::setUpperJointPositionLimits | ( | Eigen::VectorXd | lim | ) |
Set the robot upper joint position limits.
- Parameters
-
lim The robot upper position limits
- Remarks
- This functions is automatically called by loadModelFromString to set the upper joint position limits according to the urdf model
◆ skew()
|
static |
compute the skew symetry matrix of a vector. Usefull to perform cross products
- Parameters
-
vector a vector
- Returns
- The skew matrix associated to \(vecotr\)
The documentation for this class was generated from the following files:
- include/Qontrol/Model/GenericModel.hpp
- src/Model/GenericModel.cpp